
Advance positioning accuracy
Develop and evaluate 3D positioning methods that target sub-meter accuracy, including decimeter-level scientific objectives.
Advancing 3D indoor positioning with wireless sensing and artificial intelligence for the next generation of connected systems.
InSPIRE Research Centre & CYENS Centre of Excellence
Supported by the Research and Innovation Foundation of Cyprus.
Accurate location information can make indoor networks more responsive, resilient and useful. ERMIS brings together complementary wireless technologies to investigate reliable positioning in complex indoor spaces.
AdvancemEnts in 3D IndooR Positioning Methods and ApplicatIons for Next-Gen Communication Systems
Develop and evaluate 3D positioning methods that target sub-meter accuracy, including decimeter-level scientific objectives.
Investigate jammer localization, position-aided beam management and anchor auto-calibration for first responders.
Assess methods through measurements, simulations and laboratory prototypes, with open datasets and a reusable Positioning Toolbox as planned outputs.
From radio measurements to intelligent decisions, each research direction contributes a different view of the indoor environment.
Learn from radio fingerprints and combine data-driven estimates with geometric methods.
Adaptive positioningExplore reconfigurable radio environments for positioning and position-aided beam management.
Programmable propagationUse radar sensing to investigate three-dimensional localization and multi-target indoor tracking.
Spatial sensingStudy time-based ranging and 3D positioning, including comparisons with ultra-wideband systems.
Timing-based locationIoT jammer localization
RIS beam management
First-responder localization
Five connected work packages guide the project from coordination and system engineering to positioning methods and their practical use.
Project start
Methods and application reports due
Final evaluation, datasets and toolbox due
Project coordination, reporting and risk management across the consortium.
Communication, research dissemination, intellectual property management and open-science activity.
Define the technical concept and performance indicators, evaluate the methods and prepare reusable tools.
Investigate machine learning, reconfigurable intelligent surfaces, millimeter-wave sensing and fine time measurement for 3D positioning.
Apply position information to jammer localization, RIS beam management and emergency localization with anchor auto-calibration.
14 publications selected for the ERMIS project, with source links, acknowledgement evidence and publication status. Updated on 21 October 2026.
ICECCME 2026
Conference manuscript; proceedings DOI not verified
Funding footnote on first page, PDF page 1
“Research and Innovation Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Connects jamming detection confidence with spatial evidence for jammer localization in resource-constrained IoT networks.
Public author manuscript full text: Funding footnote on first page, PDF page 1. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218. The ResearchGate August date is an upload label; ICECCME programme date is 16 October 2026. Presentation is supplementary material, not a second paper.
2026 22nd International Conference on Distributed Computing in Smart Systems and the Internet of Things (DCOSS-IoT), pp. 643-652
Acknowledgment, PDF page 10
“Research and Innovation Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Combines learned position estimates, adaptive RIS anchor selection and geometric refinement for indoor positioning.
Author accepted manuscript PDF: Acknowledgment, PDF page 10. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218. Conference June 2026; repository records online publication 27 August 2026.
2026 22nd International Conference on Distributed Computing in Smart Systems and the Internet of Things (DCOSS-IoT), pp. 766-774
Acknowledgement, immediately before References
“Research and Innovation Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Develops lightweight adaptive fuzzy inference for detecting radio jamming in vehicular networks.
Public author manuscript full text: Acknowledgement, immediately before References. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218.
Sensors, 26(4), 1084
Funding Statement
“through the Research and Innovation Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Combines fingerprinting and geometric positioning through condition-aware fusion in cooperative multi-RIS indoor environments.
PubMed Central full-text published article: Funding Statement. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218.
Sensors, 26(3), 757
Funding
“Research and Innovation Foundation (project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Benchmarks generative models for IoT intrusion detection with explicit energy-efficiency evaluation.
Publisher full-text article: Funding. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218.
2026 IEEE 50th Annual Computers, Software, and Applications Conference (COMPSAC), Madrid, Spain, pp. 1896-1901
ERMIS acknowledgement has not been verified in the final published paper. The accessible author manuscript does not contain the project grant number.
Compares Wi-Fi FTM and UWB through physical ranging and indoor positioning experiments under line-of-sight and obstructed conditions.
Publisher-deposited Crossref metadata and institutional repository confirm title, authors, venue, pages, DOI and IEEE identifier. Coauthor publication list identifies the ADMNET 2026 workshop within COMPSAC. Conference July 2026; repository records online publication 20 August 2026.
Source 1 ↗ · Source 2 ↗ · Source 3 ↗ · Source 4 ↗ · Source 5 ↗
2026 International Conference on Indoor Positioning and Indoor Navigation (IPIN), Rome, Italy
Conference paper; IEEE publication pending
An accessible full manuscript is needed to verify the ERMIS acknowledgement. The paper is listed in the IPIN 2026 programme and the author publication list.
Studies single-target and multi-target 3D mmWave sensing using mechanical sensor steering and Kalman filtering.
Marios Raspopoulos’s public publication list gives the exact title, four authors and IPIN 2026 Rome. Official programme independently lists paper 23 in Session 12, mmWave, Radar & Passive Sensing, on 7 October 2026. No proceedings DOI or pages verified.
2026 IEEE International Symposium on Emerging Metaverse (ISEMV), Larnaca, Cyprus
Conference paper supplied by the project team; IEEE publication pending
Citation supplied by the project team. An accessible full manuscript is needed to verify the ERMIS acknowledgement.
Investigates mmWave human activity recognition using synthetic 3D simulation for metaverse applications.
Title, author list and paper/venue association supplied by the user. IEEE Vehicular Technology Society independently confirms ISEMV 2026 dates and UCLan Cyprus venue in Pyla, Larnaca. A public record for this exact paper was not found. ISEMV 2026 is scheduled for 22-24 October 2026. This entry is not marked as already presented.
2026 Mediterranean Artificial Intelligence and Networking Conference (MAIN), Palermo, Italy, pp. 1-10
The accessible author manuscript acknowledges other funding. An ERMIS acknowledgement in the final published version remains unverified.
Compares adaptive fuzzy and neuro-fuzzy detectors using baseline-aware features for IoT jamming attacks.
Publisher-deposited Crossref metadata confirms exact title (including Based), three authors, venue, dates, pages and DOI.
2025 Asian Conference on Communication and Networks (ASIANComNet), pp. 1-9
Acknowledgement, immediately before References
“the Research and Innovation Foundation (Project: EXCELLENCE/0524/0218)”
Read acknowledgement source ↗
Evaluates topology-aware reinforcement learning and tail-risk measures for RIS beamforming.
Public author manuscript full text: Acknowledgement, immediately before References. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218. Conference year 2025 and Crossref published date 29 December 2025; university repository records online release 30 June 2026.
IET Communications, 19(1), e70096
Acknowledgements; also repeated in the article Funding declaration
“through the Research and Innovation Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Combines access-point clustering with learned localization for device-to-device cell-free networking.
Publisher full-text article: Acknowledgements; also repeated in the article Funding declaration. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218. Published 14 October 2025. Publisher spells the first author Iakovos Ioannou.
2025 International Conference on Indoor Positioning and Indoor Navigation (IPIN), Tampere, Finland, pp. 1-6
Funding footnote, PDF page 1
“Foundation (Project: EXCELLENCE/0524/0218).”
Read acknowledgement source ↗
Examines clustering methods for locating multiple indoor targets from mmWave radar measurements.
Author accepted manuscript PDF: Funding footnote, PDF page 1. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218.
2025 21st International Conference on Distributed Computing in Smart Systems and the Internet of Things (DCOSS-IoT), pp. 489-498
Acknowledgement, immediately before References
“Research and Innovation Foundation (Project: EXCELLENCE/0524/0218)”
Read acknowledgement source ↗
Uses detection and localization information to reroute RPL traffic around jammed nodes.
Public author manuscript full text: Acknowledgement, immediately before References. Explicitly acknowledges ERMIS grant EXCELLENCE/0524/0218. Conference June 2025; the ResearchGate April label is an early upload date.
2025 IEEE International Symposium on Emerging Metaverse (ISEMV), Honolulu, HI, USA, pp. 46-54
The full paper was not publicly available for checking its acknowledgement. The repository grant association is not treated as actual-paper verification.
Studies mmWave crowd tracking for metaverse environments using sensor-error models and simulated movement.
Publisher-deposited Crossref metadata confirms all three authors, title, pages, DOI, IEEE identifier and 2025 conference. DOI record created 12 January 2026; keep conference citation year 2025, with online release separately noted. Conference held 19-20 October 2025; university repository records online release 12 January 2026.
No publications match these filters. Try another keyword or reset the filters.
Open “Acknowledgement & sources” to see each paper’s funding evidence. Papers awaiting acknowledgement verification or IEEE publication are labelled explicitly. Presentations and manuscript versions are counted once. Download the complete bibliography.
Bringing together indoor positioning, wireless communications and intelligent IoT security across InSPIRE and CYENS.
 Coordination
Project Coordinator
InSPIRE Research Centre
Research profile Dissemination
 & IPR Manager
CYENS Centre of Excellence
Research profile Research leadership
CYENS Principal Investigator
CYENS / University of Cyprus
Research profile IoT security
IoT Security Research
CYENS / University of Cyprus
Research profileCollaborators supporting the project’s research and applications. Formal consortium partners are InSPIRE and CYENS.
Open datasets and a Positioning Toolbox are planned to support reproducibility and future work in indoor localization.
The planned release will bring together project data and reusable algorithms. Public download links will be added when the release is available.
D4.2Final report on novel 3D positioning methodsD5.2Final report on position-based applicationsD3.3Critical evaluation reportD3.4Open dataset and Positioning ToolboxD2.3Dissemination, communication and exploitation reportDates correspond to project months M23 and M24. Public release links will appear here when available. IPR is managed in line with RIF requirements through the Central Knowledge Transfer Office.
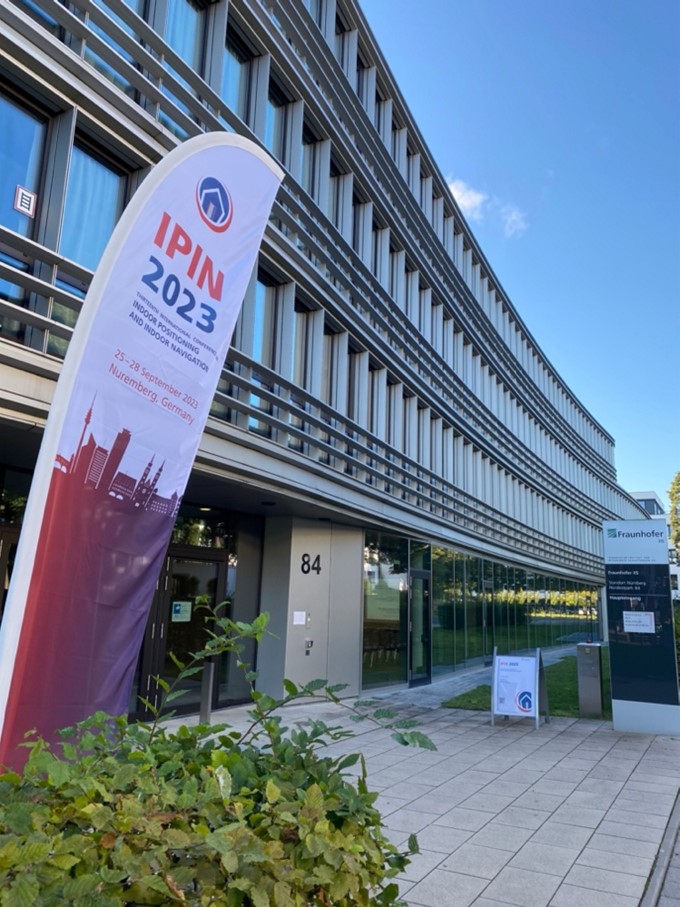
ERMIS builds on earlier work in millimeter-wave sensing and indoor localization. These photographs document IPIN 2023 in Nuremberg, before the ERMIS project began.
The publication collection brings together the project’s selected research outputs.
Explore ERMIS publications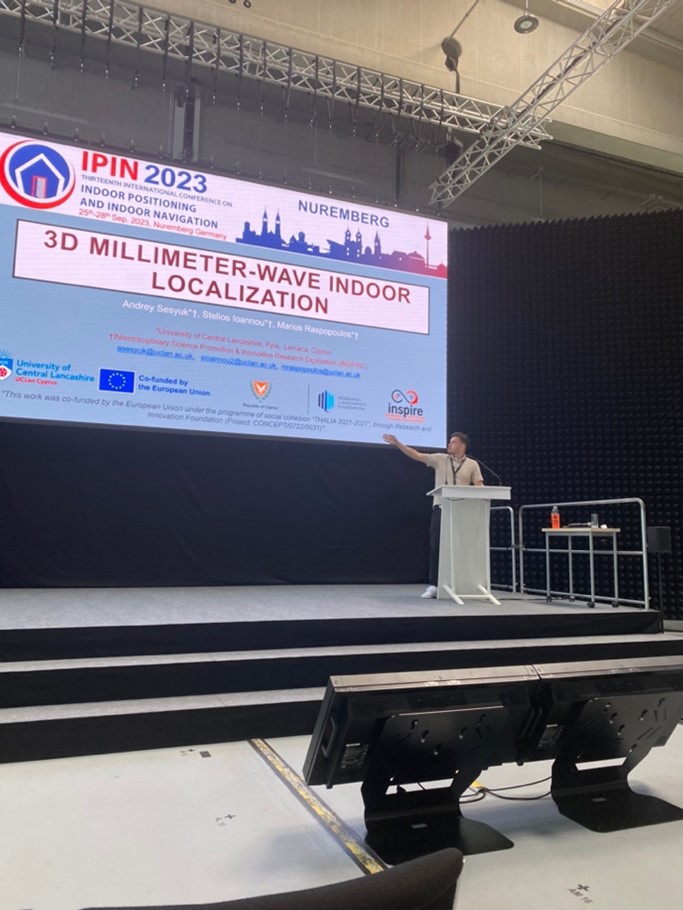
For research collaboration, project information or dissemination enquiries, contact the project team.